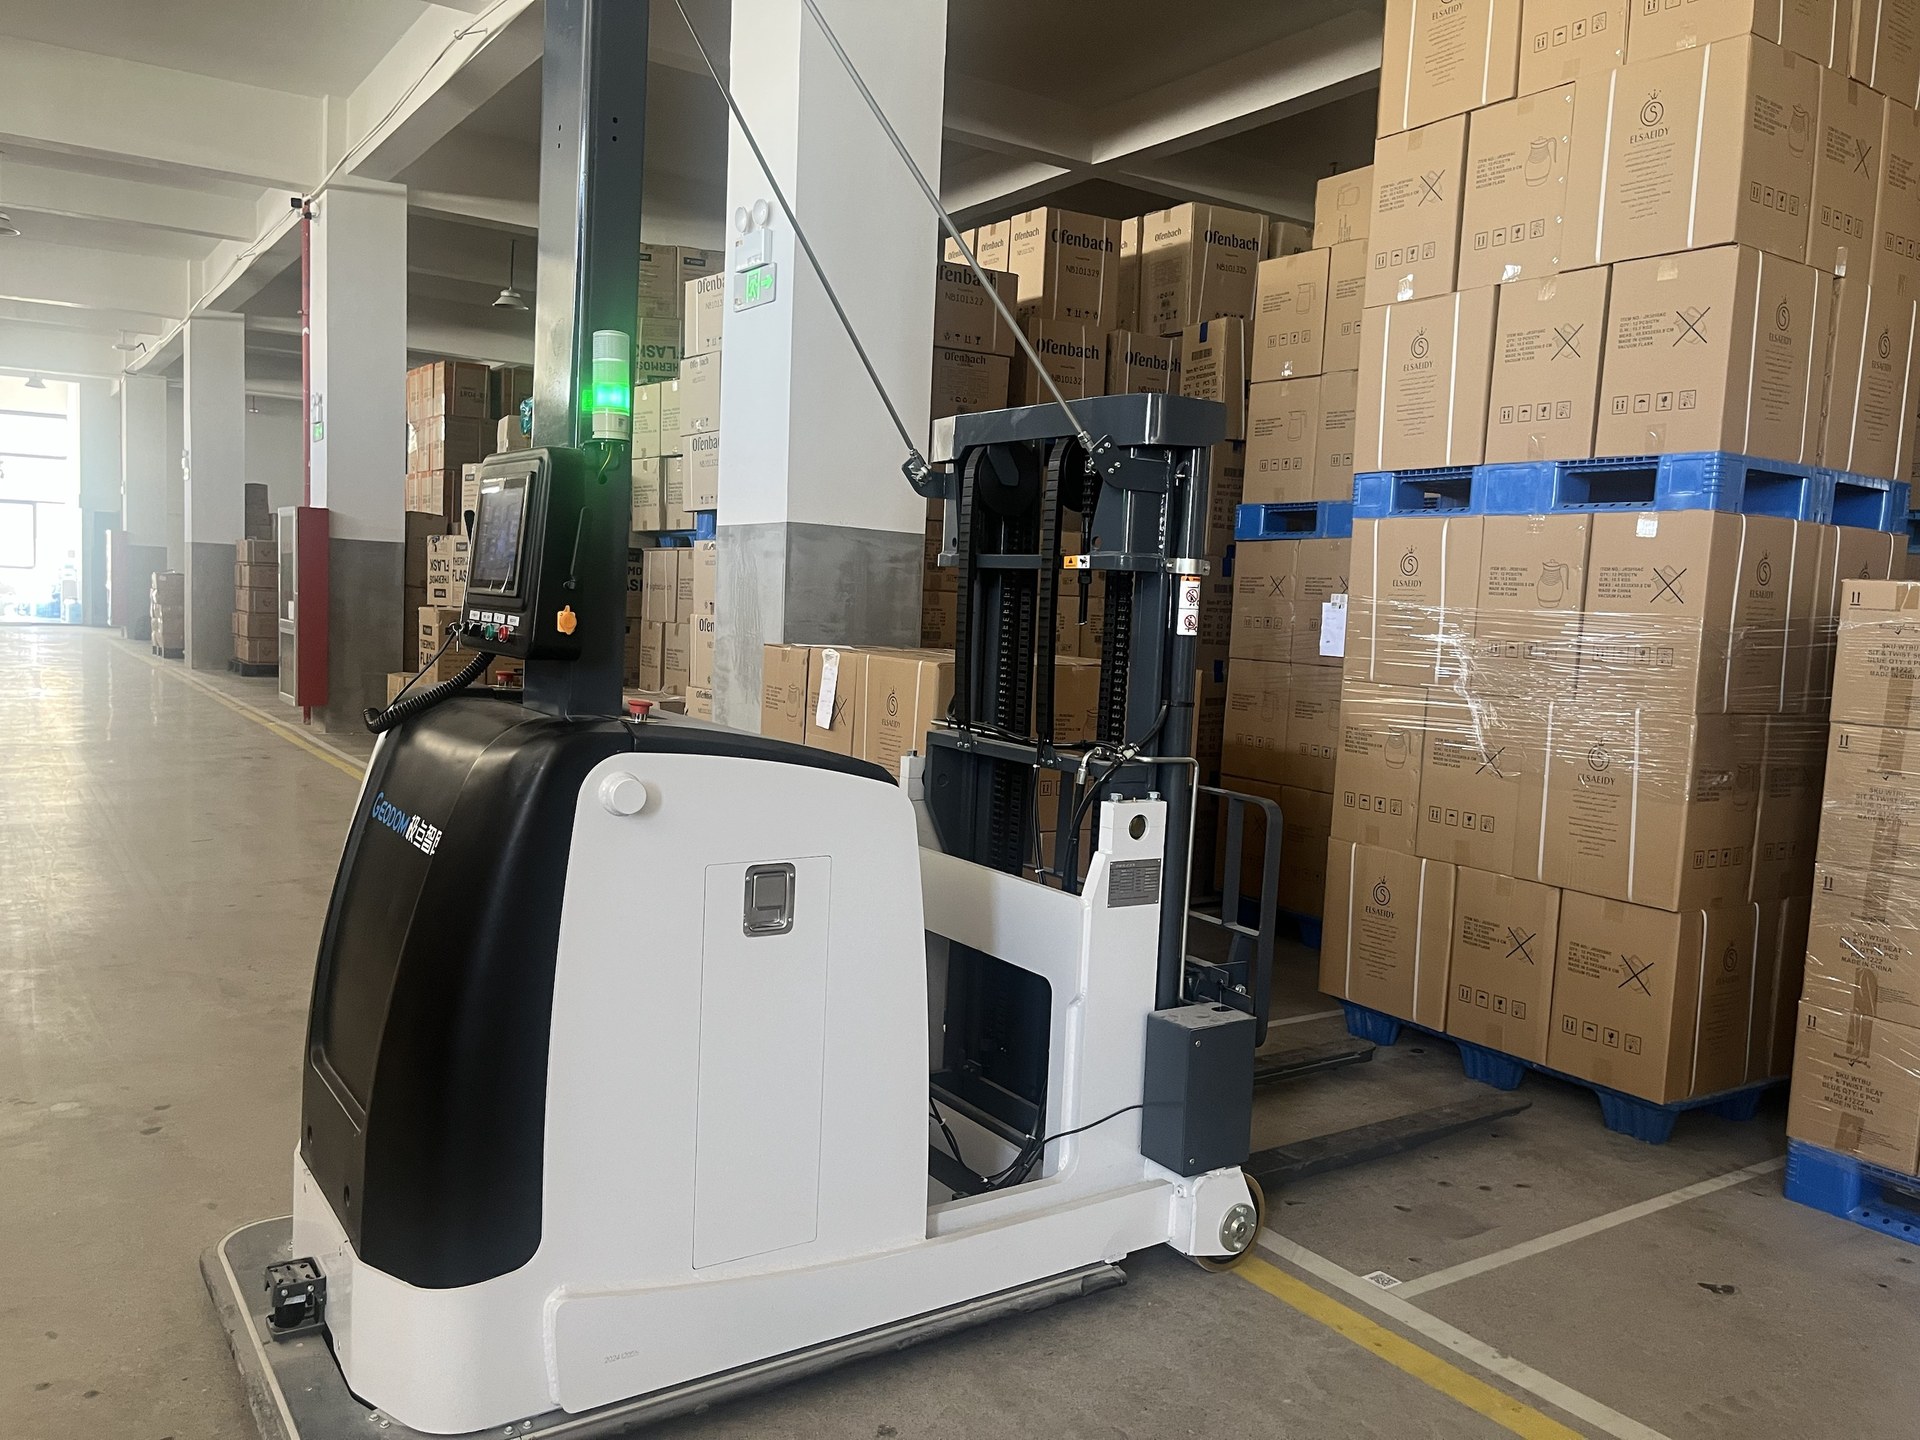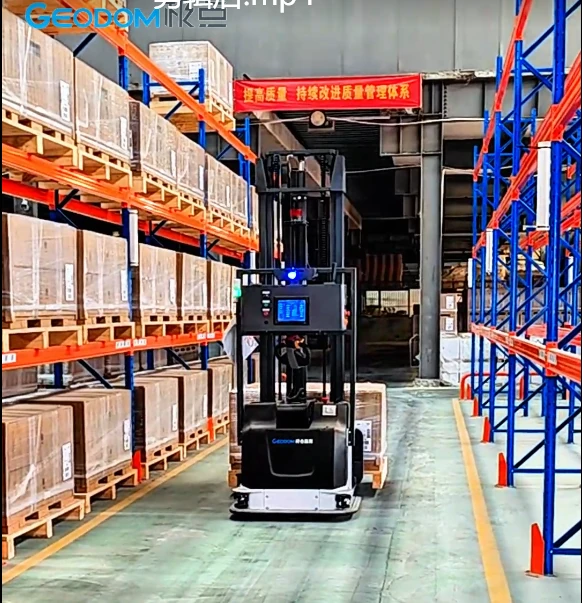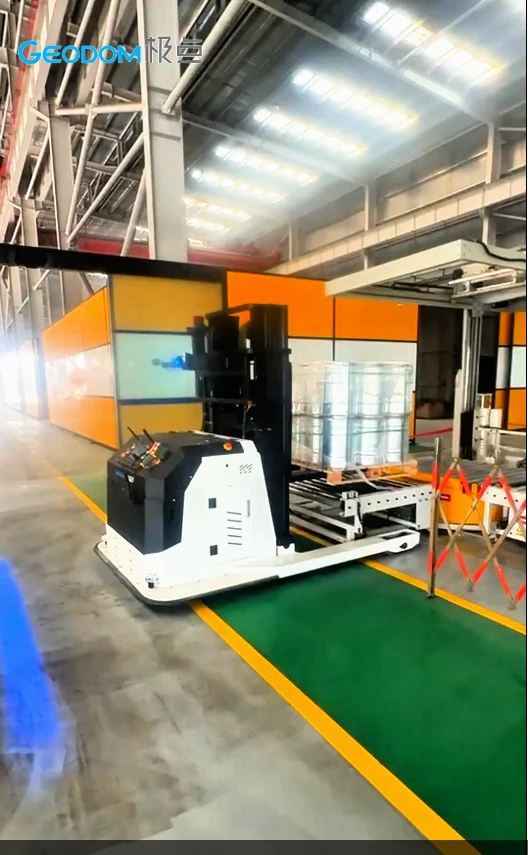
A robot signals when a pallet is complete. An AGV carries the finished load to the inbound buffer and supplies an empty pallet from the destacker to the robot.
The two vehicles alternate tasks to support the workshop's continuous production schedule.